Goal oriented AI
An exploration in code of Goal Oriented Action Planning (GOAP), a way to build AI with fairly emergent behaviour. From the world and the objects around it, the agent works out the best strategy to reach its goal; here, gathering wood.
2020 Games Table
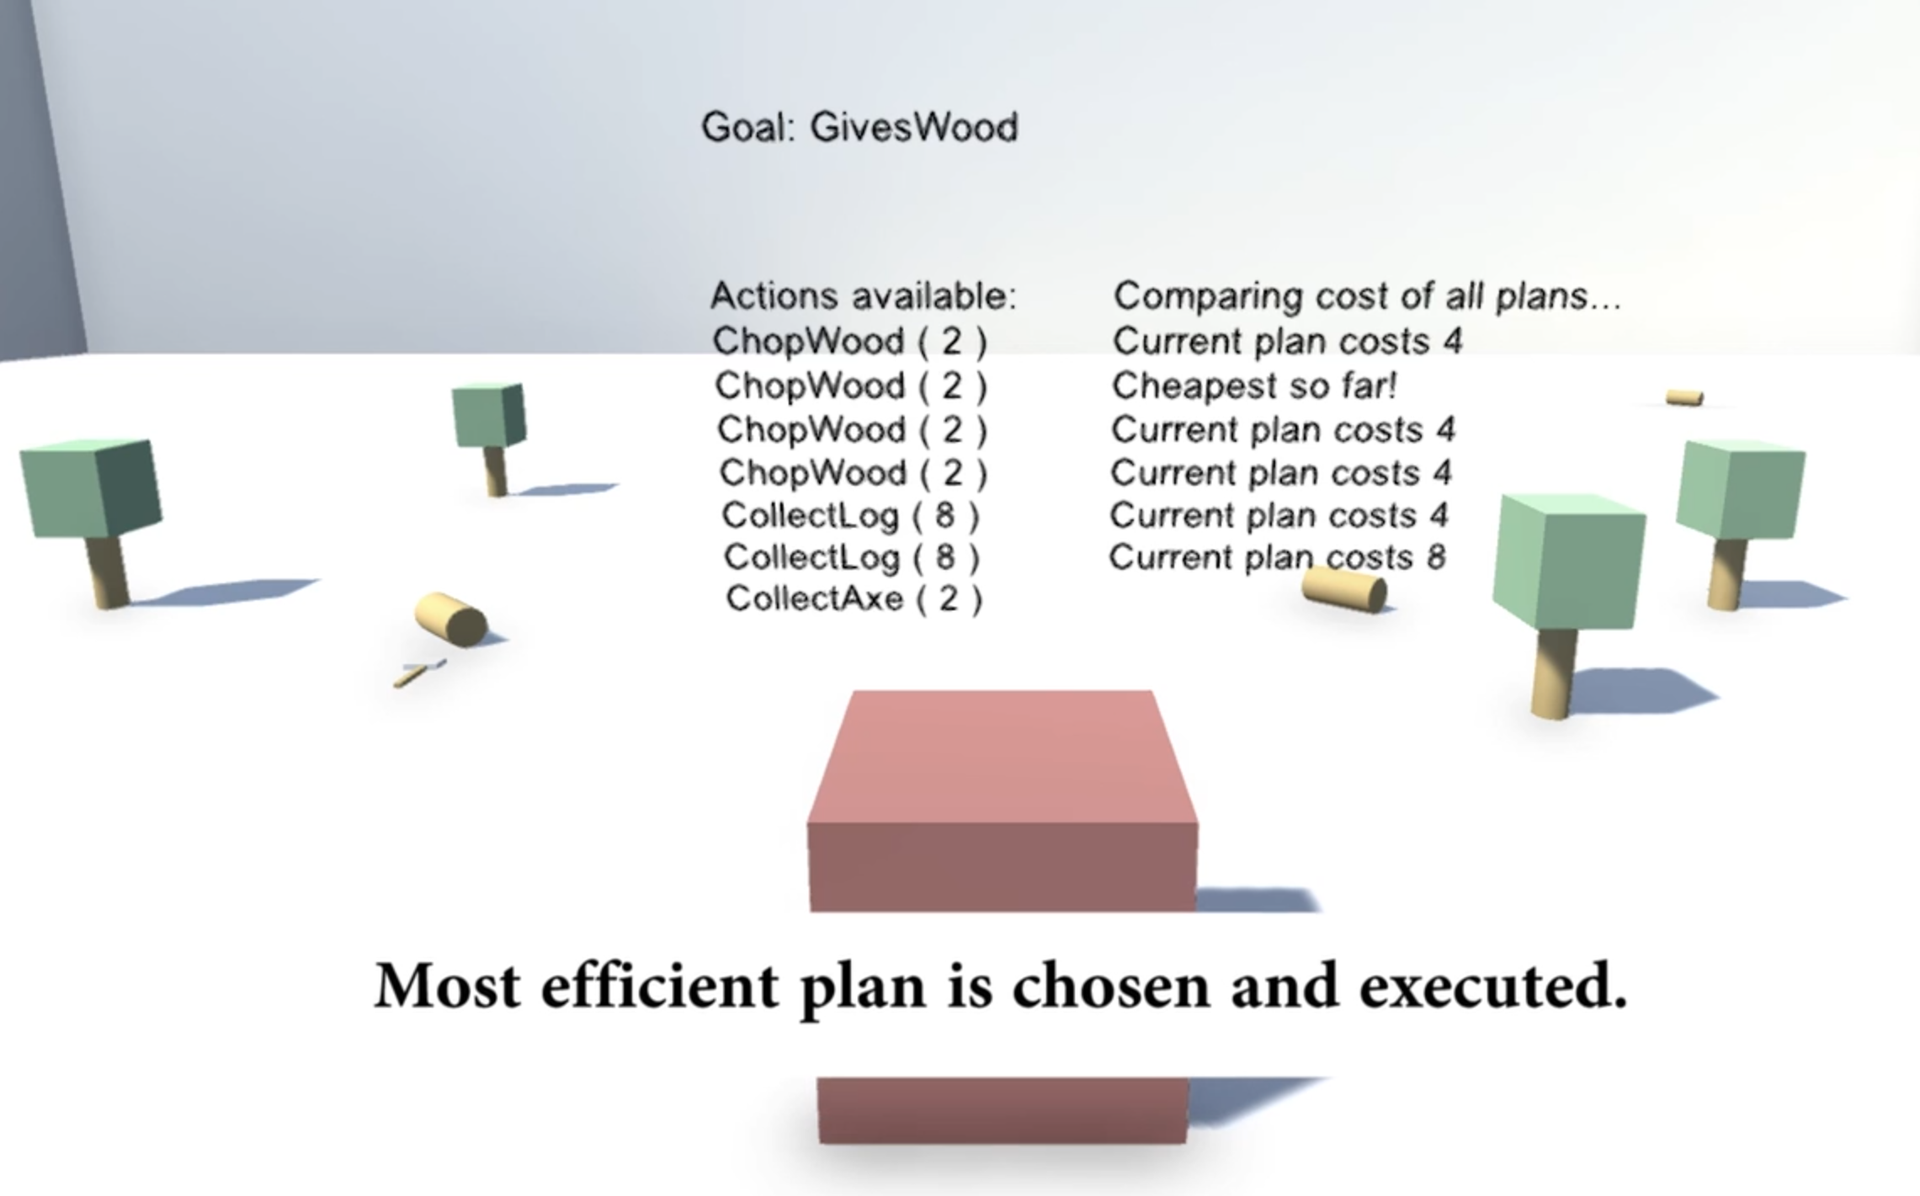
Every available action has a cost and a precondition. Collecting logs from the ground needs nothing but costs more than chopping wood, and chopping wood needs an axe first. Over several prototypes in Unity and C#, I improved the performance and my control over the agents.
The system became the rabbits’ brain in A Leap Forward, and I have used it since in other games that needed good or experimental AI.